Lab note · 26 Oct 2026 · simulation
A bad lesson never reached the robot.
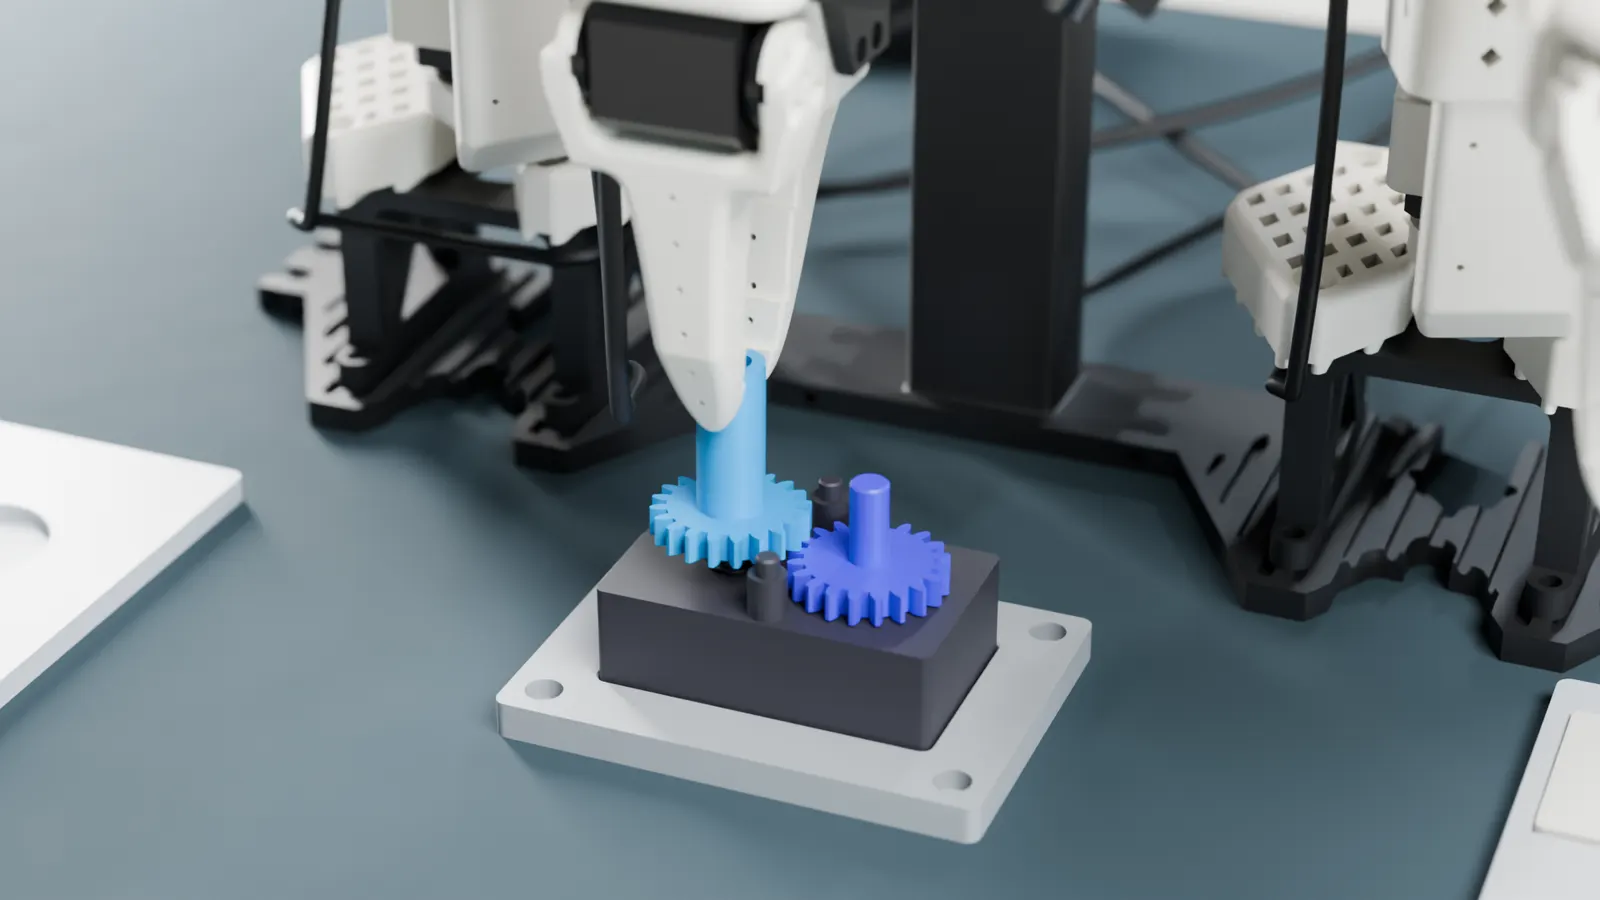
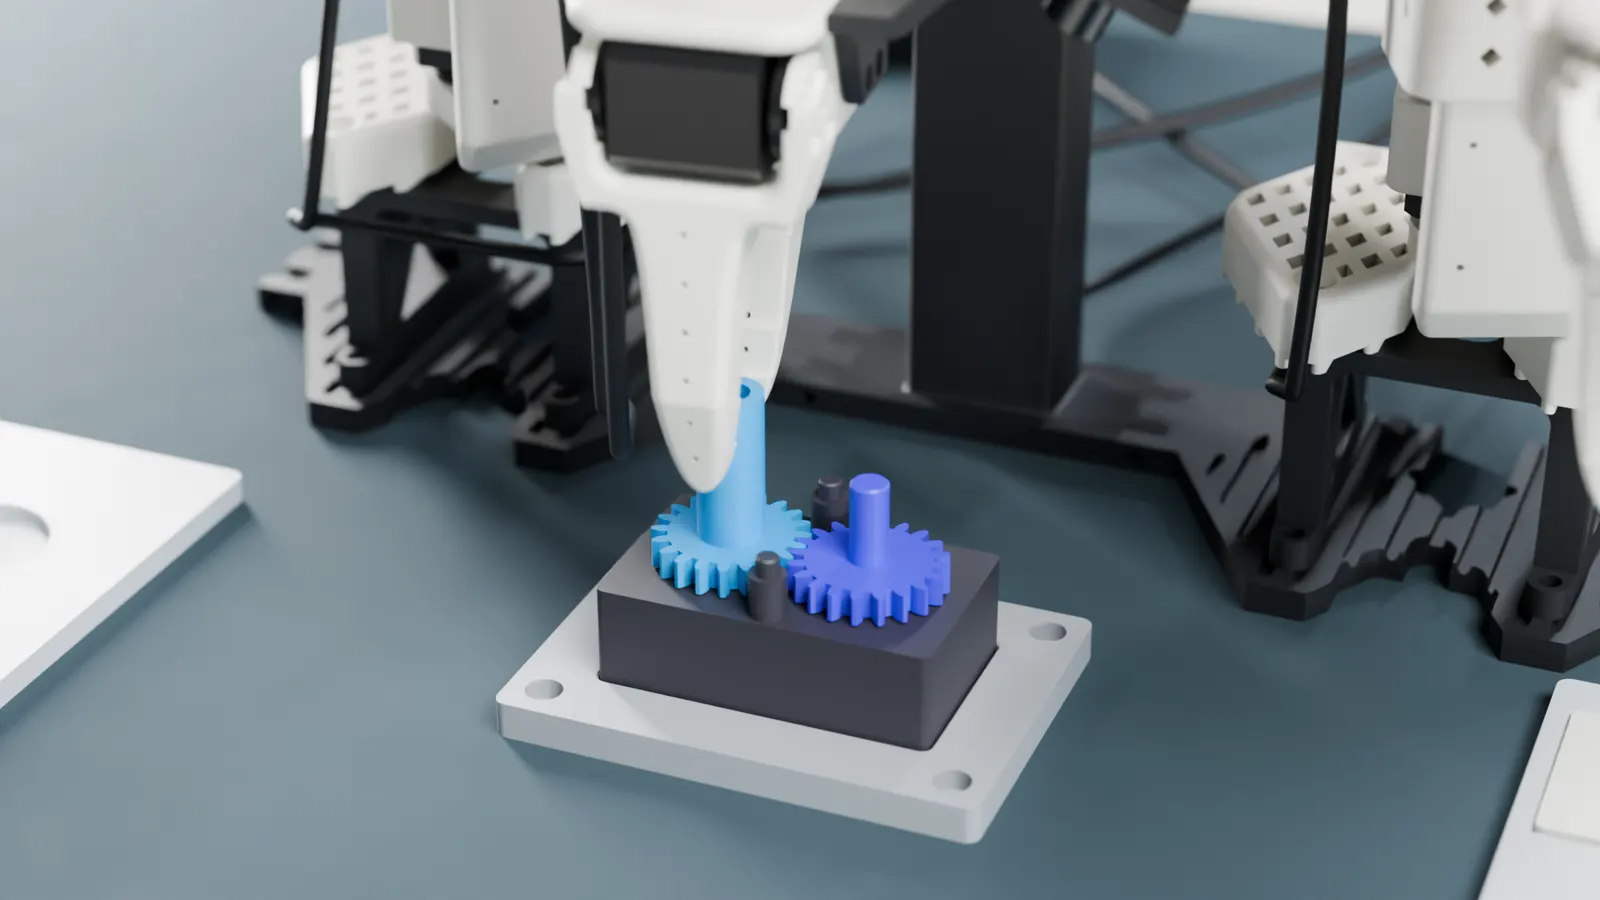
The same bench, the next step: gear B onto gear A. Version 1 left gear B on gear A's teeth, and the pair stood by. Two lessons were tried for it.
“Keep turning while you lower it.”
The version our script wrote from these words failed in both simulated copies it was tried in, 0 of 2. It was refused before anyone was asked to approve it, and the robot kept the version it had.
When AI models wrote from the same words in trials, 4 of 5 wrote versions that worked. The copies test the version that was written, not the words.
“Let it rest on the teeth with a light press, then turn it slowly, up to a tooth either way, until it drops in.”
Our own script wrote version 2 from these words. It passed 8 of 8 copies from where the pair stood, 6 of 6 from the task's start and 4 of 4 in the scene where version 1 was corrected. The founder approved it, and gear B went in.