Lab notes.
Every lesson and bench note, newest first, as recorded. All of it in simulation; our first real arm is being built.
Lessons
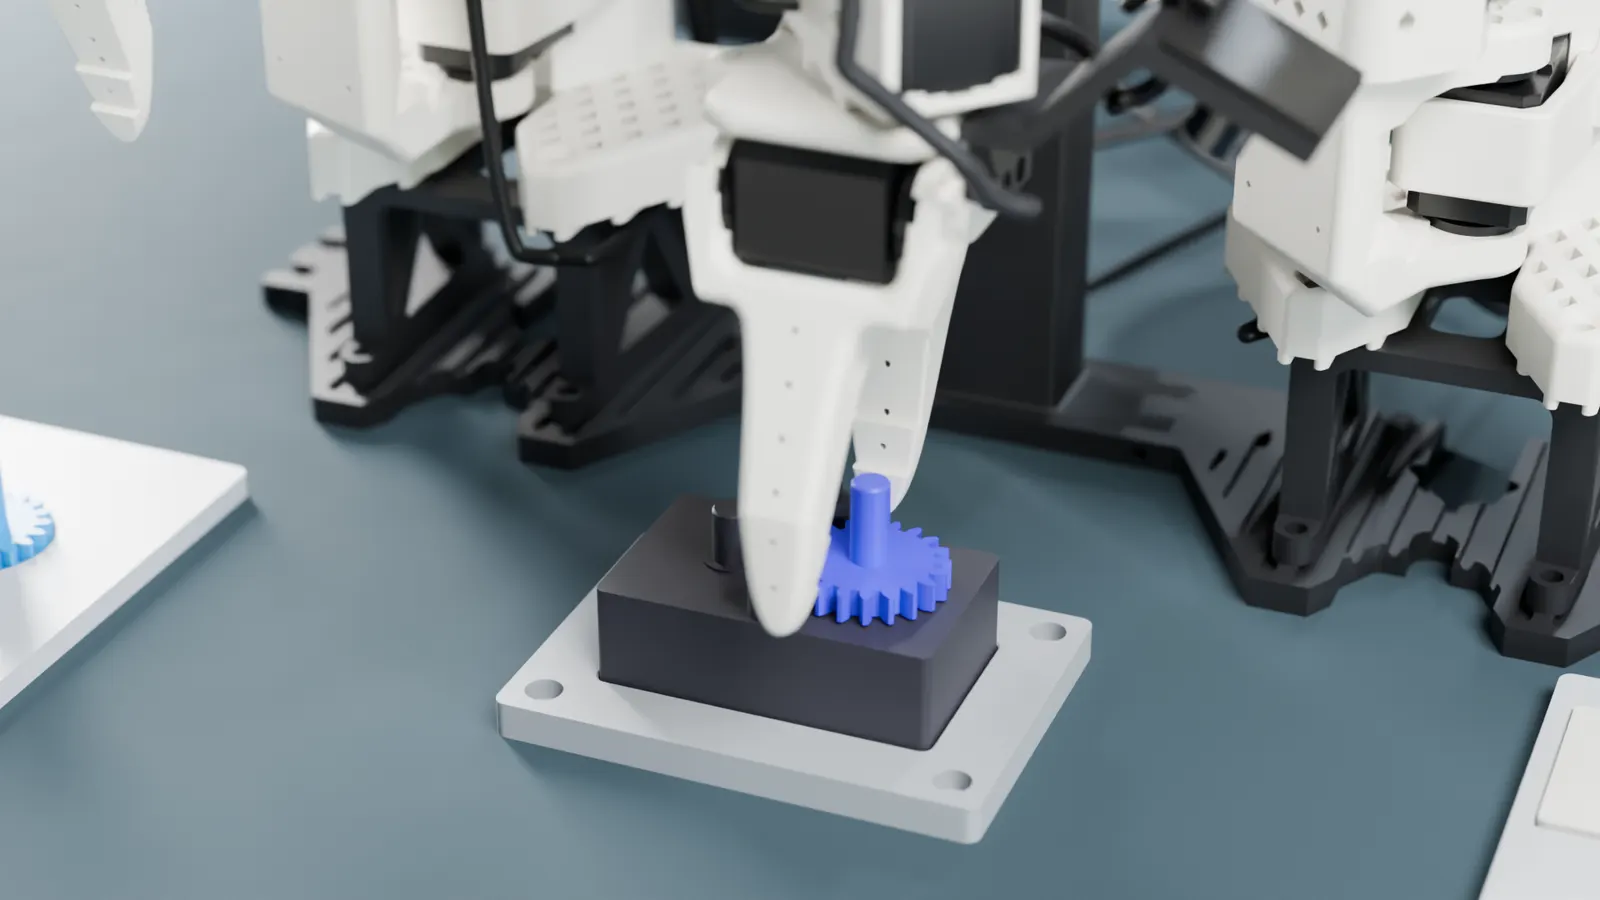
One sentence, and the shaft went in.
Version 1 missed the bore. An AI model wrote version 2 from the founder's correction in 43 s; it passed 8 of 8, 6 of 6 and 4 of 4 simulated copies, and the founder signed it.
Read the note →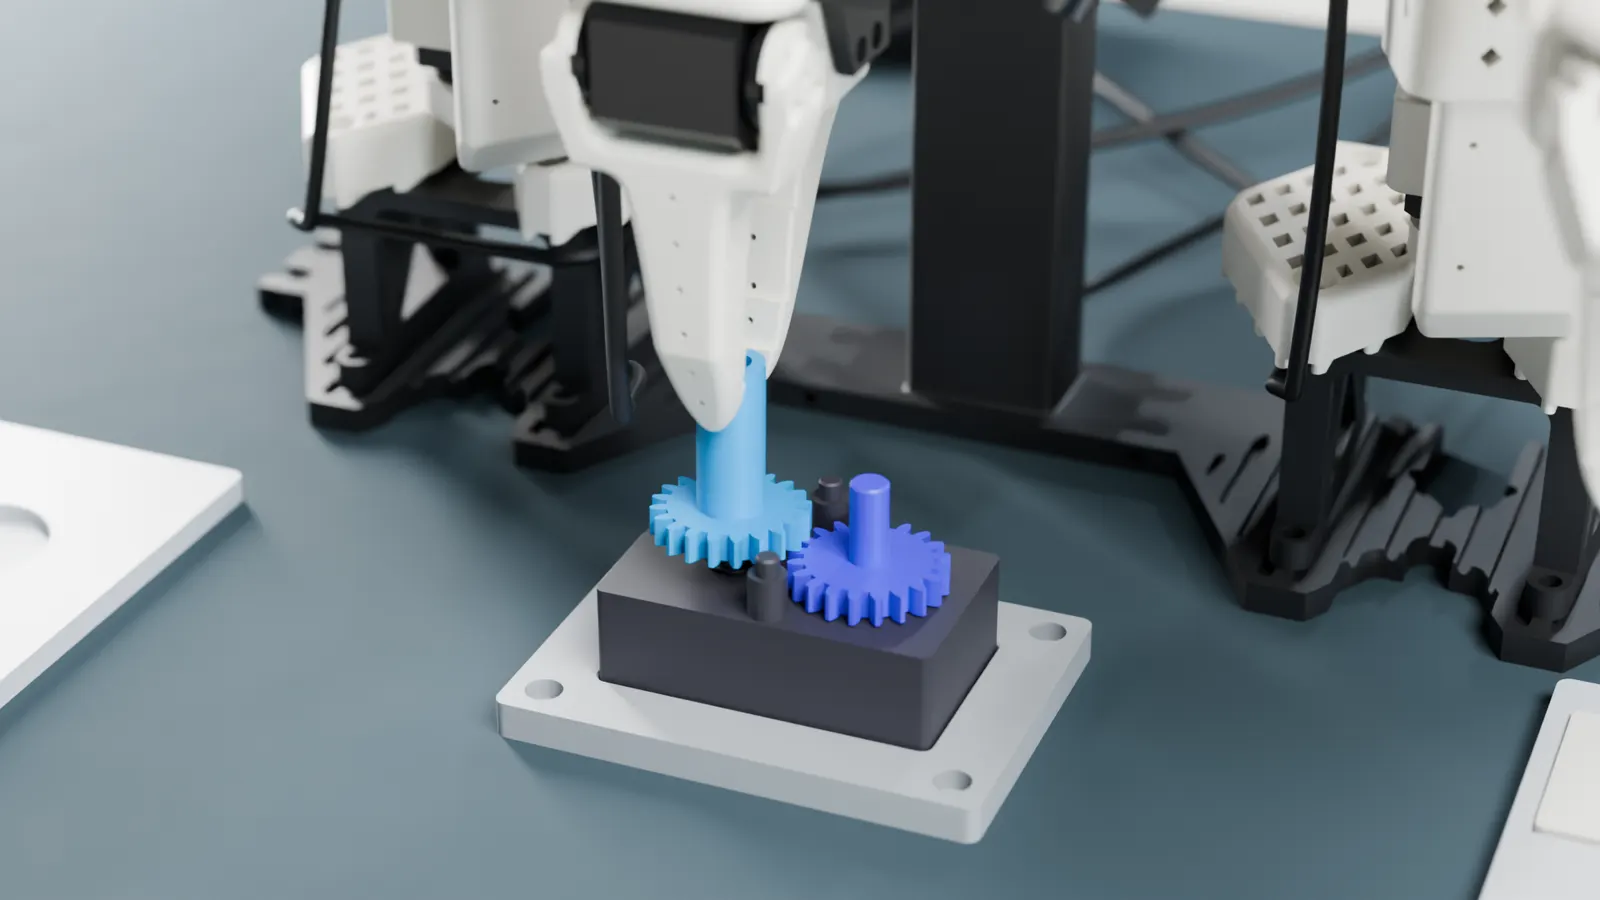
A bad lesson never reached the robot.
“Keep turning while you lower it.” The version our script wrote from it failed both copies, 0 of 2, and was refused before anyone was asked. Better words were signed, and gear B went in.
Read the note →
Failed at 14:45:33. Fixed, tested and signed by 14:47:51.
Our first lesson signed on the rig computer: the clip, the robot's own recording, the agent's calls and what we measured.
Read the note →
Bench notes · dates in Sydney
- NextThe first real arm on the bench.
- 22 OctThe log tool reads a team's ROS 2 bags into the competence map.our own data
- 20 OctAn arm behind ROS 2 stood by, took a new version and succeeded, judged on its own sensors.simulated arm
- 18 OctArms that LeRobot drives connect through one adapter.simulation
- 17 OctHostile corrections contained in all 8 cases. Nothing went into use without a person's approval.simulation
- 17 Oct16 of 16 live fault tests passed in one run.simulated arm
- 17 OctFirst lesson signed on the rig computer: version 2 in use, then 3 of 3.simulated arm
- 13 OctAll 6 steps of the loop built and measured.simulation